
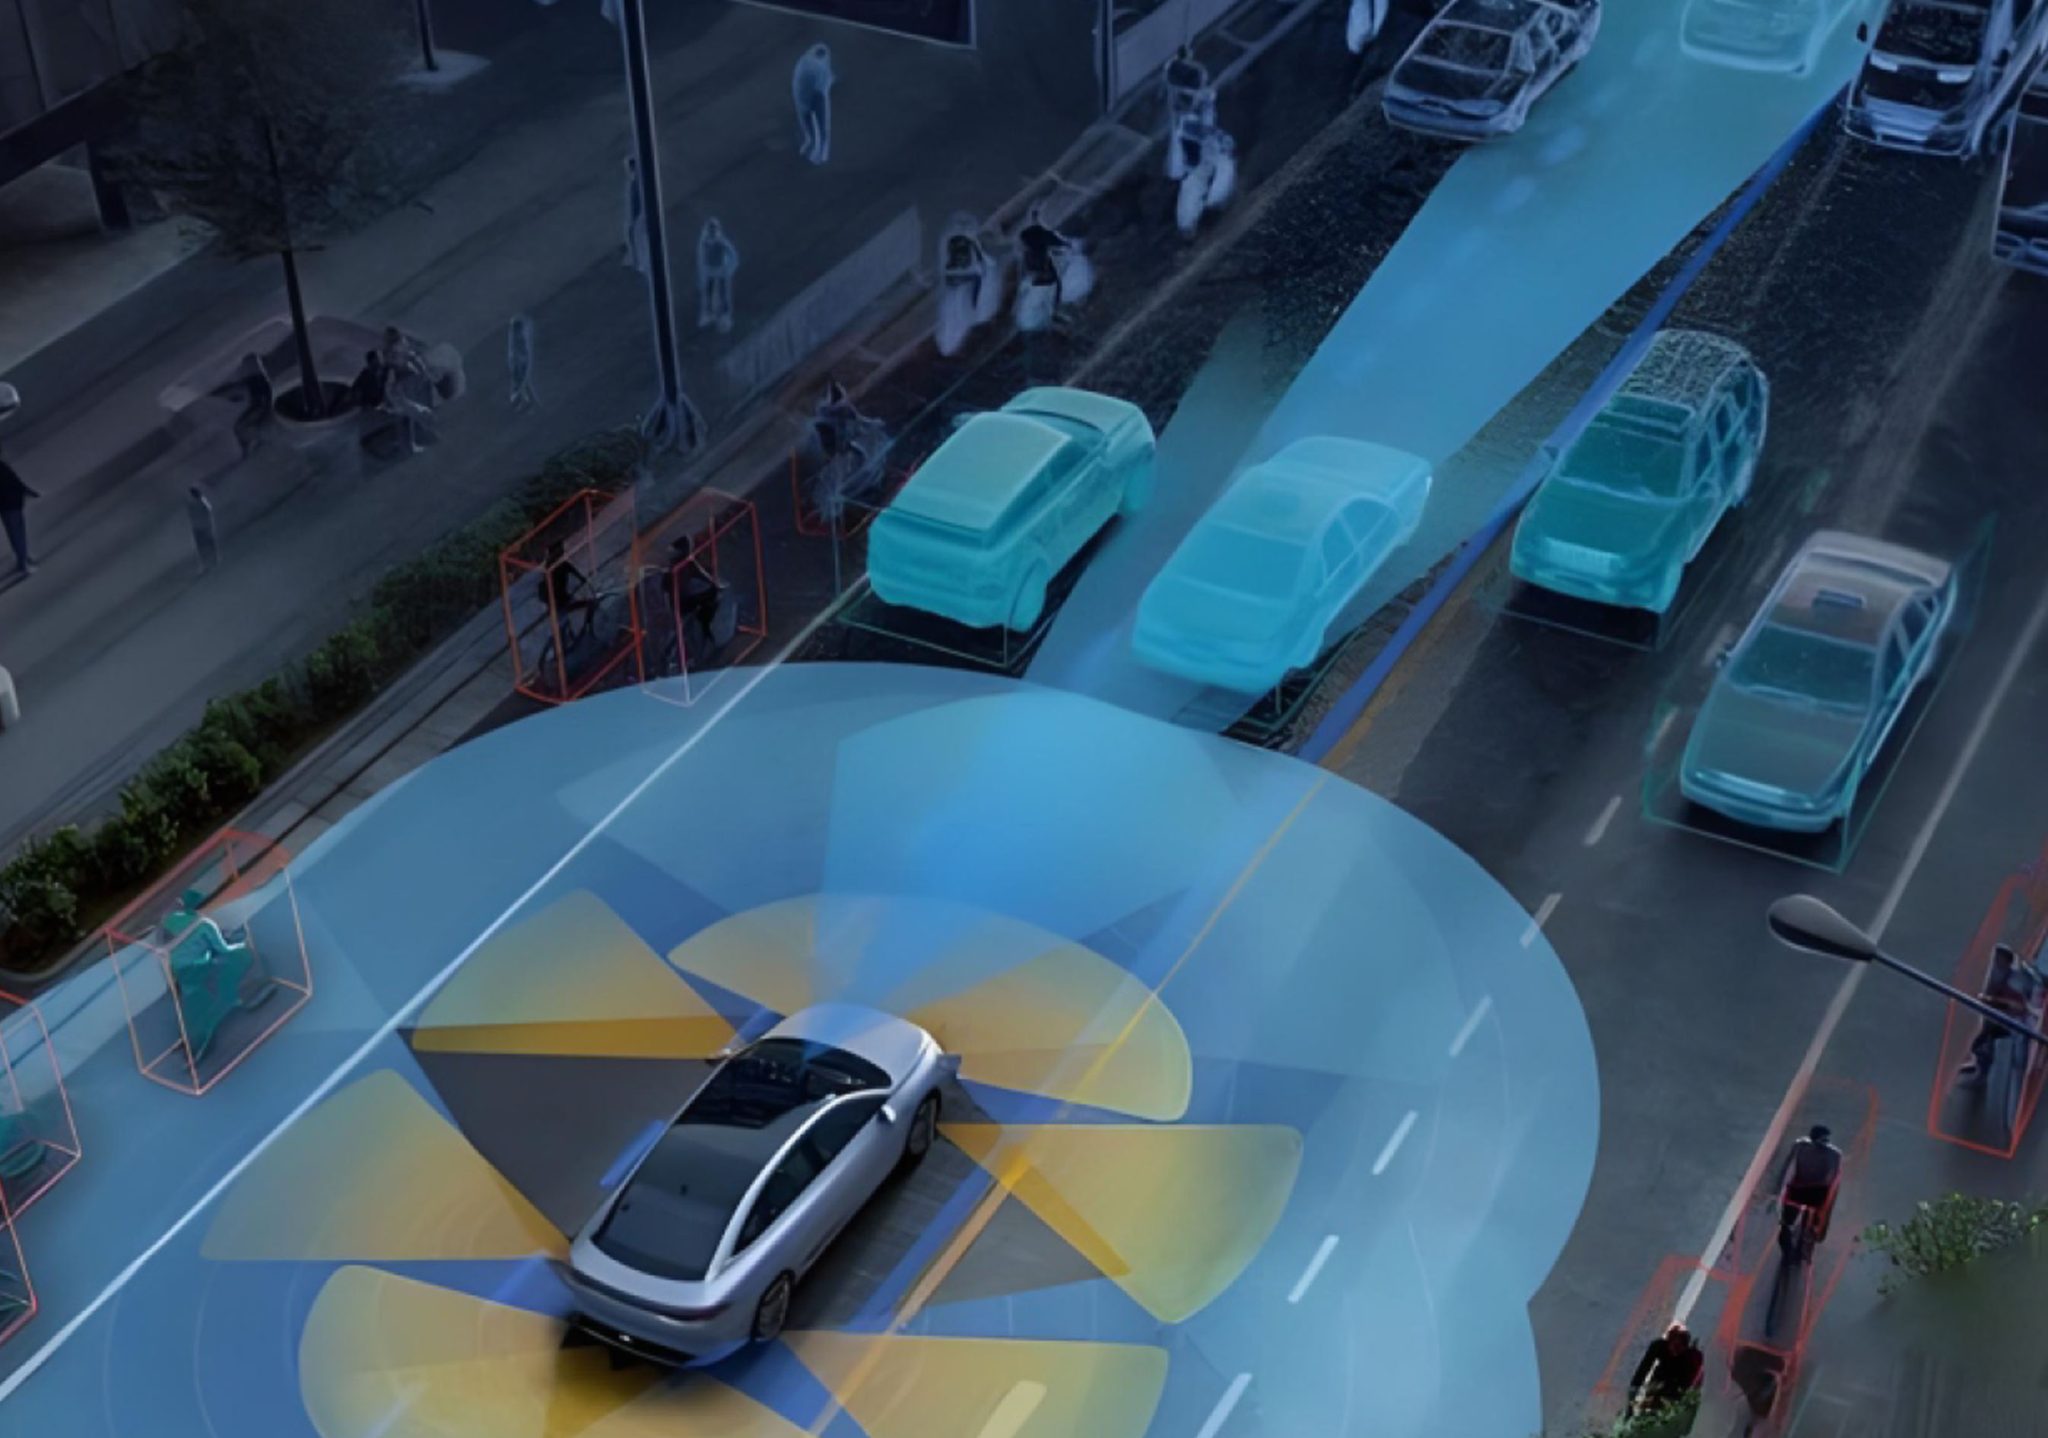
Comparative opening: what this piece will do
This article compares tightly coupled GNSS/INS fusion options to help you pick an anti-jam antenna strategy that actually improves kinematic reliability. I’ll lay out practical trade-offs, not theory-heavy fluff, and show how a robust sensor stack—starting with a high-quality mems inertial sensor—changes the outcome on the road, offshore, or on the tarmac. Expect clear contrasts, quick takeaways, and a bias toward solutions that perform under duress.
Why tight coupling beats loose coupling for anti-jam work
Tightly coupled GNSS/INS integration blends raw satellite observations with inertial measurements so the system can keep moving even when some satellites are jammed or spoofed. Where a loosely coupled approach drops to a degraded mode when fewer satellites are available, a tight scheme keeps the estimator stable by using IMU data directly in the measurement update. That stability is what gives you consistent kinematic solutions during interference—so your positioning stays viable when it matters.
A practical comparison of antenna strategies
Three mainstream antenna strategies tend to appear in designs: conventional high-gain antennas, adaptive array/beamforming antennas, and hybrid anti-jam antennas with embedded null-steering. Here’s how they stack up in real use:
– Conventional: simple, cost-effective, but limited under directed interference. Best when your operational environment is benign.
– Adaptive array / beamforming: powerful against localized jammers; typically larger and more complex in processing and calibration.
– Hybrid null-steering: balances size and resilience; often pairs well with a tightly coupled GNSS/INS stack and a precise MEMS IMU for short-term hold.
Match the antenna choice to mission profile: small UAVs favor compact hybrids; fixed installations can take advantage of arrays. Keep in mind the estimator algorithms—Kalman filter tuning matters more for tight coupling than the antenna alone.
Components that matter: sensors and software
Choose an attitude sensor that complements your antenna. A high-bandwidth attitude sensor with low bias instability reduces drift during GNSS outages and eases the pressure on carrier-phase smoothing. Combine that with a MEMS IMU that has known noise figures, and your fusion filter will have the reliable inputs it needs.
Real-world anchor: lessons from airport interference
When the drone-related shutdown at Gatwick Airport in late 2018 highlighted the fragility of navigation and airspace control, operators learned that redundancy and resilient fusion were not optional. High-accuracy positioning systems that paired robust antenna designs with tight GNSS/INS fusion were better able to preserve navigation integrity during localized interference events—proof that hardware and algorithm choices matter in live operations.
Implementation pitfalls and how to avoid them
Common mistakes include over-relying on antenna gain, ignoring IMU quality, and failing to validate filter behavior under partial GNSS visibility. Calibrate biases, evaluate vibration sensitivity, and run scenario tests that simulate band-limited jamming. Don’t skimp on cross-checks between carrier-phase smoothing and inertial dead-reckoning—those redundancies catch edge cases. — Remember, a system that looks good on paper can fail under realistic multi-source interference unless you stress-test it.
Comparative summary and what to prioritize
Put simply: tight GNSS/INS fusion plus a hybrid null-steering antenna gives the best balance of size, cost, and resilience for kinematic platforms. If weight and space are constrained, prioritize a better IMU and tighter estimator tuning over marginal antenna gain increases. For fixed or manned platforms where volume allows, adaptive arrays with beamforming provide superior directed-jammer suppression.
Advisory close: three golden rules for choosing your stack
1) Validate sensor-grade: require published noise and bias specs for the IMU and attitude sensor; demand real vibration and temperature test data. 2) Stress the estimator: run tight-coupling Kalman filter scenarios with reduced satellite sets and simulated jammers to confirm graceful degradation. 3) Match antenna to mission: select null-steering or beamforming when directed interference is likely; use compact hybrids for constrained platforms.
Choose these priorities right and you’ll get predictable kinematic performance—and that’s what teams need in the field. Archimedes Innovation. —